Land
Unmanned ground capability for tasks where persistence, payload carriage or reduced human exposure matters.
Land autonomy must cope with terrain, obstacles, communications limits, payload variability and close interaction with people and infrastructure. ECADSOL therefore treats mobility, autonomy, payloads, operator control, safety and field support as a single system problem.
Design Concepts
In Development
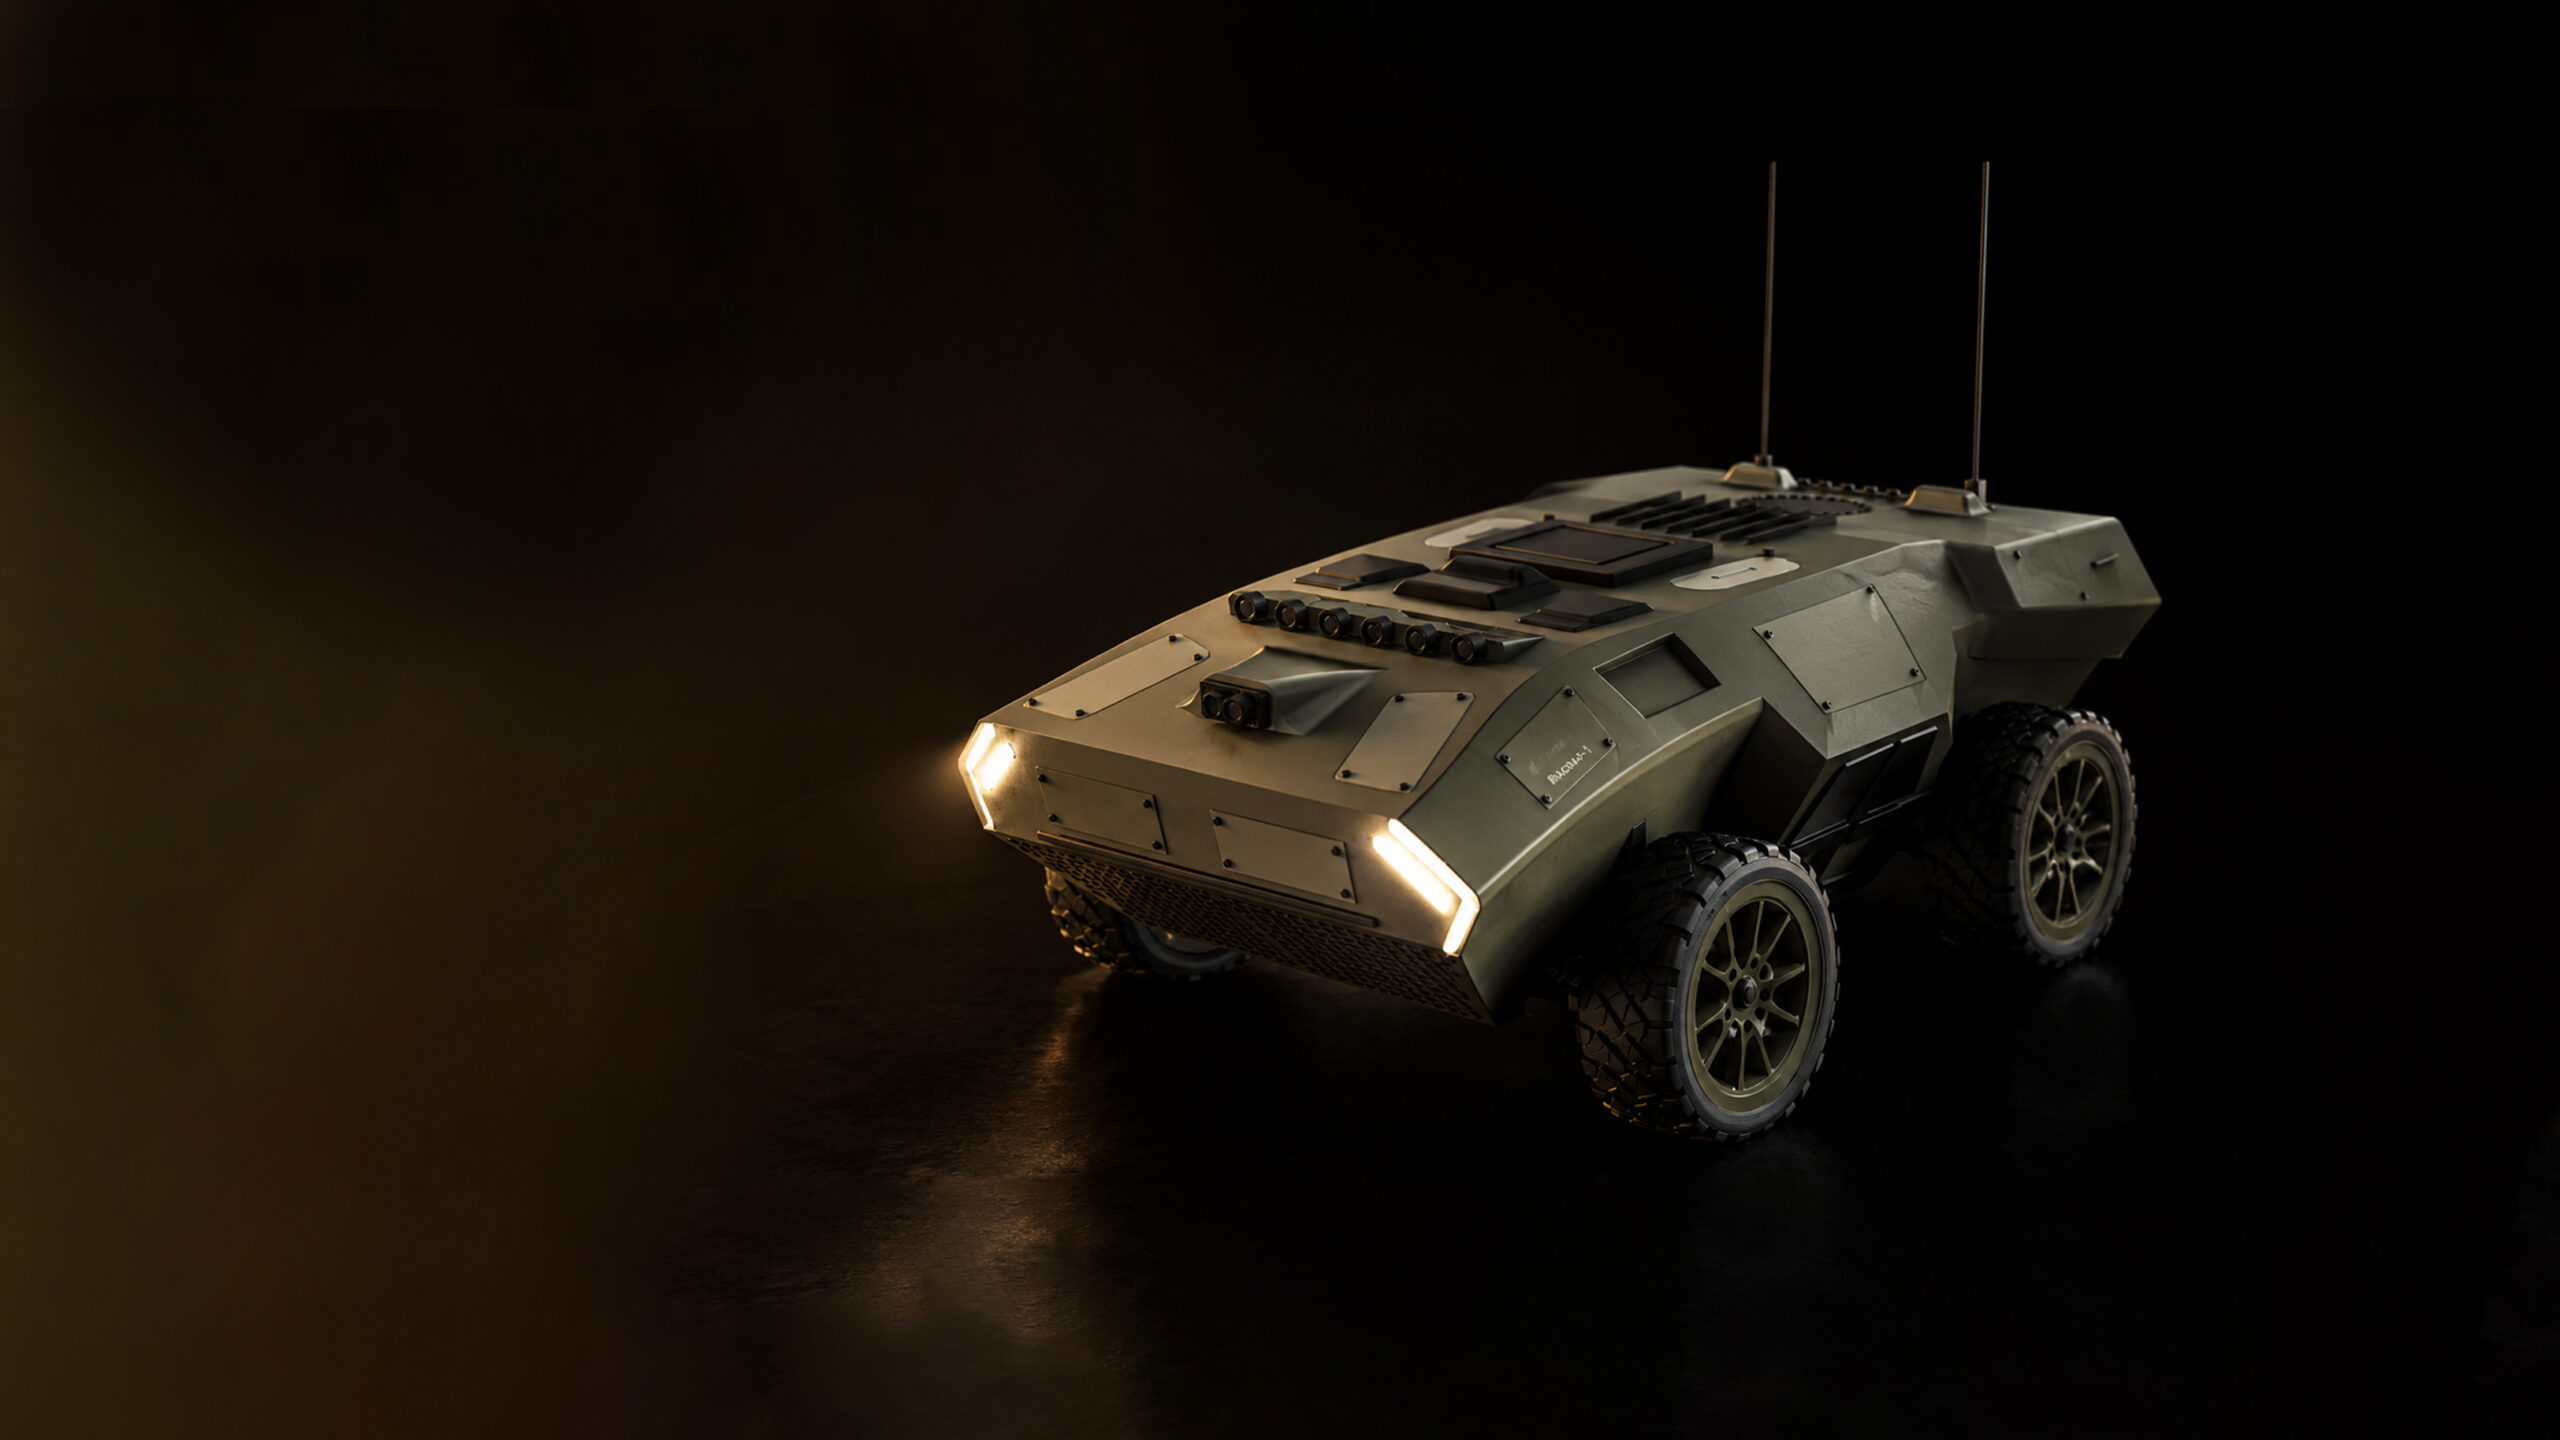
BAOBAB-1 - TITAN
Tracked unmanned ground vehicle
BAOBAB-1 is ECADSOL's flagship land-domain UGV. Its design intent
is a modular tracked platform able to support mission-specific payloads
for ISR, logistics resupply, engineering support and perimeter security.
The concept prioritises modularity, survivability, maintainability and
integration with the wider command and autonomy architecture. Design
intent includes controlled mission kit reconfiguration and a support model
that can progressively enable routine maintenance within the customer's
own or local support ecosystem, subject to the final programme architecture.
Integrated by Design
Land systems design priorities.
- Mobility and terrain access
- Payload and mission-module interfaces
- Operator-supervised autonomy and safe-stop behaviour
- Secure communications and degraded-mode operation
- Field maintainability and recovery
- Integration with Nexus C2/C4ISR and Osiris autonomy services